How Long Can a Humanoid Robot Operate Per Charge?
Humanoid robot battery life is usually measured in hours per charge, and most systems operate for roughly 2 to 8 hours depending on size, mobility, onboard computing, and task load. A robot that stands, walks, uses perception cameras, and runs advanced control algorithms consumes far more power than one performing light, stationary interaction. For buyers, developers, and operators, the key question is not just total battery capacity, but how that stored energy translates into practical runtime during real work. Understanding operating time helps with deployment planning, charging schedules, staffing, and system design. This article explains typical humanoid robot runtime, the main factors that affect battery performance, and practical ways to estimate and extend operating hours in research, service, and commercial environments.
How Long Do Humanoid Robots Typically Run on One Charge?
Typical Battery Runtime Across Different Humanoid Robot Applications
Most humanoid robots run between about 2 and 6 hours per charge during active use, while lighter-duty interaction tasks may stretch closer to 8 hours. Runtime changes with application. Robots used for research labs, mobility testing, and dynamic locomotion often drain batteries faster because balancing, walking, and repeated joint motion require constant power. Service or reception robots that spend more time standing, speaking, and making limited gestures usually run longer. Performance-focused deployments, such as entertainment routines, can also shorten runtime because frequent full-body motion raises motor demand. In practice, operators should estimate battery life based on the robot’s real duty cycle: how much time it walks, manipulates objects, senses its environment, and processes data continuously.
Battery Capacity, Energy Density, and Operating Time Explained
Battery runtime comes from a simple relationship: stored energy divided by average power draw. It’s capacity is often expressed in watt-hours, showing how much energy the pack can deliver. Higher capacity generally means longer operation, but battery weight also matters because heavier packs increase total mass and can raise the energy needed for movement. Energy density describes how much energy a battery stores relative to its size or weight, which is especially important in full-size humanoids where space and balance are limited. Operating time also depends on discharge efficiency, motor control strategy, and peak loads. A robot with a large battery may still have shorter runtime if it performs power-intensive walking, manipulation, or perception-heavy tasks.
What Factors Affect Humanoid Robot Battery Runtime?
Movement, Payload, and Task Intensity
The largest driver of humanoid robot power consumption is movement. Walking, turning, recovering balance, crouching, and raising arms all demand continuous torque from multiple joints. Faster motion and frequent acceleration increase current draw, which shortens runtime. Payload also matters: carrying tools, displays, or other equipment forces actuators to work harder, especially in the legs and torso. Task intensity adds another layer. Repetitive manipulation, expressive gestures, and full-body demonstrations consume more energy than stationary conversation or monitoring. Even posture affects efficiency, since dynamic balancing and transition movements use more power than stable standing or seated operation. To predict battery life accurately, evaluate the robot’s actual physical workload rather than relying on idle or standby figures.
Computing Systems, Sensors, and Environmental Conditions
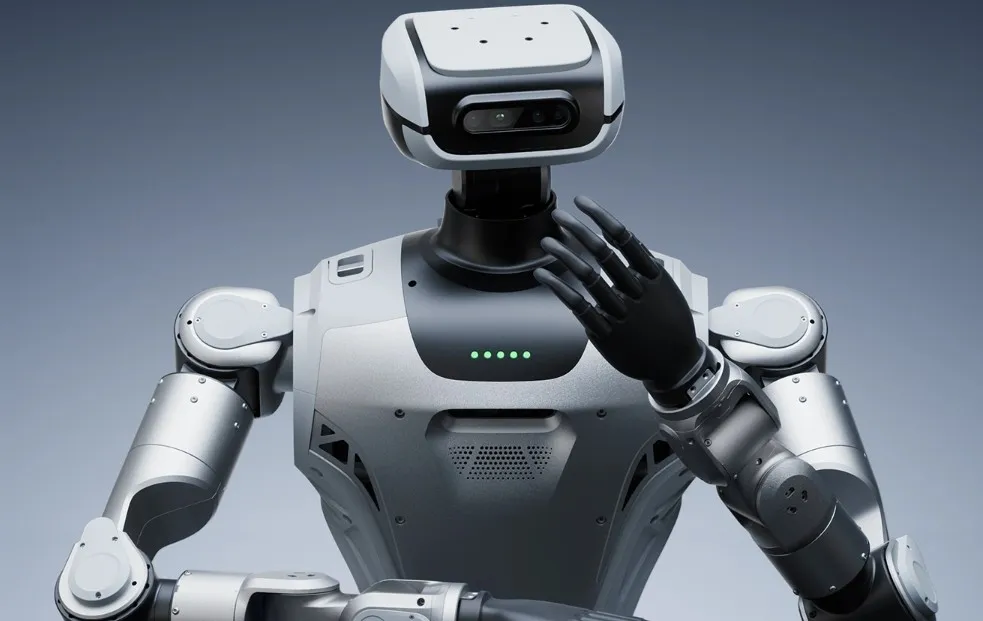
Battery life is affected not only by motors, but also by computing and perception hardware. Humanoid robots often run motion control, vision processing, navigation, speech interaction, and safety monitoring at the same time. Higher compute loads increase power draw, especially when depth cameras and external sensors remain active continuously. Environmental conditions also influence runtime. Cold temperatures can reduce usable battery output, while heat may lower efficiency and require extra thermal management. Uneven floors, ramps, or crowded spaces can raise energy use because the robot must make more balance corrections. In a platform such as LimX Oli, independent compute for motion control and perception, dual Intel® RealSense™ D435i depth cameras, and a self-developed 6-axis IMU support advanced capability, but those active systems also shape total operating time.
How to Estimate and Extend Humanoid Robot Operating Time
Calculating Battery Runtime and Optimizing Power Consumption
A practical battery runtime estimate starts with watt-hours divided by average watts consumed during a representative task. If a robot uses 900 Wh and the average system load is 300 W, expected runtime is about 3 hours. The key is measuring real operating power, not just rated maximum draw. Track separate scenarios such as idle standing, guided interaction, walking, and manipulation to build a realistic duty-cycle model. To extend operating time, reduce unnecessary movement, limit peak-speed actions, and switch off unused peripherals or compute modules when possible. Efficient gait tuning, smoother motion planning, better task sequencing, and scheduled low-power pauses can all lower average consumption without reducing practical productivity in day-to-day deployment.
Quick-Swap Battery Design and Practical Applications of LimX Oli
Quick-swap battery design is one of the most effective ways to keep a humanoid robot working through longer shifts. Instead of waiting for a full recharge, operators can replace the battery pack and resume tasks with minimal interruption. This approach is especially useful in exhibitions, research programs, training environments, and performance settings where uptime matters more than a single continuous run. LimX Oli fits these scenarios well because it combines full-size humanoid capability at 165 cm with up to 31 DoF, bilingual voice interaction, and flexible sensor integration through USB 3.0 and 3.2 interfaces. Its foldable seated storage design also simplifies transport, staging, and battery servicing for single-person operation across changing locations.
Conclusion
A humanoid robot can typically operate for about 2 to 8 hours per charge, with most active full-size systems falling closer to the middle of that range. The most accurate answer comes from matching battery capacity to the robot’s actual power draw during walking, manipulation, sensing, and computing. Movement intensity, payload, onboard processors, camera usage, and environmental demands all directly affect runtime. For operators, the best strategy is to measure real duty cycles, calculate average consumption, and design workflows around charging or battery replacement. Quick-swap systems, efficient motion control, and smart peripheral management can significantly improve practical uptime. When runtime is evaluated realistically, teams can deploy humanoid robots more reliably for research, service, interaction, and performance applications.